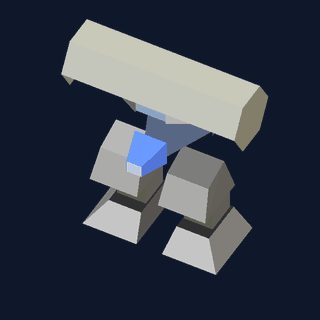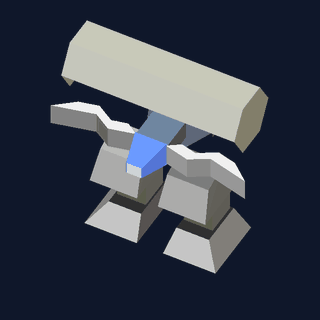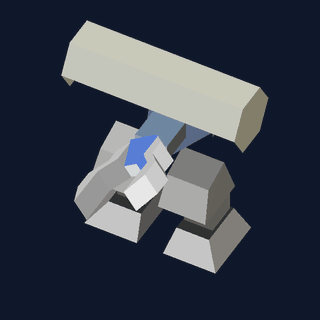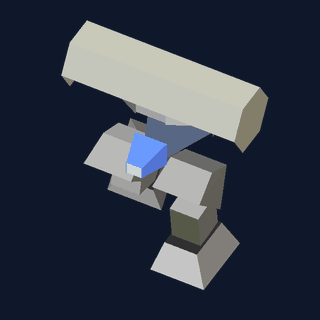
COB-exact: timeline 1:1 from ARMASER.COB (rev31.gp3, the 3.1 balance) — the first walking bot of the series. Its MotionControl is not a parametric gait but a 16-pose stop-motion walk baked right into the bytecode (1040 ms per cycle) — replayed here 1:1. Plus the radar-jammer head: extend, splay the prongs, spin.
Animation
PNG frames
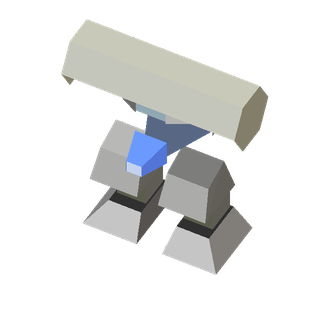
Frame 0 / 1700.00 s
COB timeline (ARMASER.COB)
- 0.04–2.12 s — walks two full gait cycles (16 bytecode poses, 1040 ms per cycle, pelvis bob 0.5 elmo)
- 2.12–2.71 s — stopping: all six leg pieces ease to zero at 200°/s (MotionControl stop branch)
- 2.8–3.55 s — Activate: the fork head extends 3 elmo out of stowage (4 elmo/s)
- 3.55–4.31 s — the two prongs splay open (−119°/+117° at ≈155°/s)
- 4.33–6.33 s — the head spins at 100°/s — jammer radar active
- 6.33–7.93 s — Deactivate: the spin settles into the full turn (360° = 0)
- 7.93–9.30 s — prongs close (174°/171°/s), head retracts (4.35 elmo/s)
- 9.30–11.38 s — walks two more gait cycles
The gait poses are turn-now jumps (70 ms holds) — stop-motion, just like the original interpreter. The cycle deliberately starts at the pose with pelvis height 0, so stopping settles cleanly into the zero point.