COB-exact: timeline 1:1 from armbeac.cob (Go/Stop, disassembled with _cob_dis.py — no .BOS ships). The FBI calls it XLR Radar Tower, the community knows it as the Alien Beacon: a fork mast carrying four nested gyro rings (circ1–circ4, each the parent of the next so their rotations compose). Smoke, hit and death scripts are engine-driven and not part of this loop.
Animation
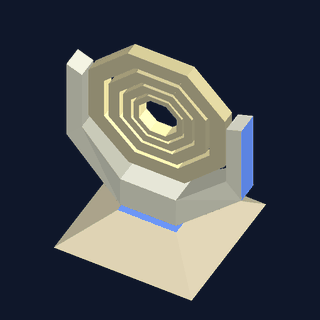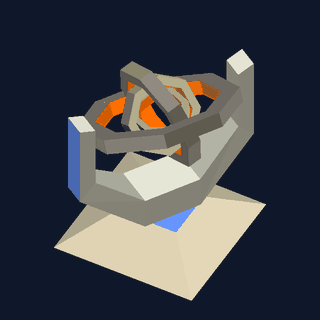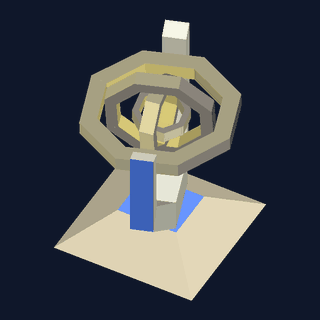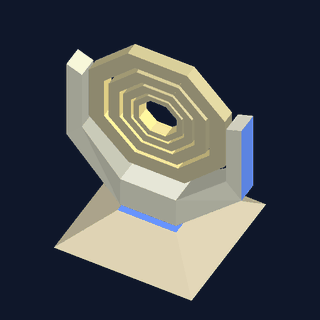
PNG frames
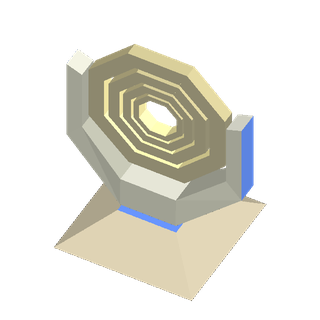
Frame 0 / 1990.00 s
COB timeline (armbeac.cob)
- 0.00–0.40 s — rest pose (all rings flat and nested at the 3DO zero point)
- 0.40–4.15 s —
Go: spin-up ramp — fork y 15→30°/s; circ1 x 20→35°/s, circ2 y 25→40, circ3 x 30→45, circ4 y 35→50 (each ring staggered 750 ms, two ramps each — every duration equals itssleep) - 4.15–11.51 s — steady spin: the rings tumble on alternating axes (x/y/x/y) while the whole mast turns at 30°/s. Every ring pulses on the engine's
glowtexture wave (8 frames × 400 ms, the measured lamp cadence) - 11.51–12.82 s —
Stop: rings freeze at the accumulated angle (spin <0>), sleep 300 ms, then wind back to 0 at 35/40/45/50°/s in compiled order; the fork ramps down to 10°/s for 250 ms and freezes - 12.82–16.00 s — rest again — the loop restarts seam-clean (frame 200 = frame 0, pixel-verified)
Spin speeds are BAM/s straight from the COB (65536 = 360°). The steady-spin hold is a solved loop calibration: its length makes the fork's freeze angle exactly 360°, so the rest pose is the true 3DO zero — all COB rates and stage durations stay literal. The wind-back returns along the shortest path from the wrapped angle (documented renderer convention).