Live preview (JavaScript)
The loop is played live in your browser from the validated loop table (the same data the reference render below was made from); the badge on the player is its self-test (seam + motion probes). The pre-rendered reference follows.
Fast Assist-Repair Kbot — from the unit’s FBI. It strides, then deploys its arms and nano lathes to work on the project — the gait-only first version left the work pose out.
COB-exact: timeline 1:1 from armfark.cob (gait + deploy (COB VM), disassembled with _cob_dis.py). The nano beam itself is engine FX (drawn between the lathe muzzles and the workpiece), so the preview shows the compiled arm/torso work pose that aims them; there is no Fire script — the laser has no reload choreography in the COB.
Animation
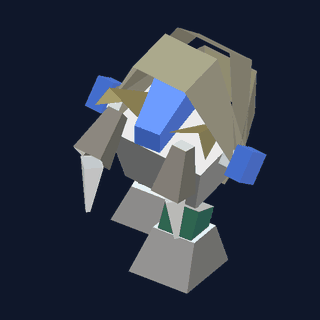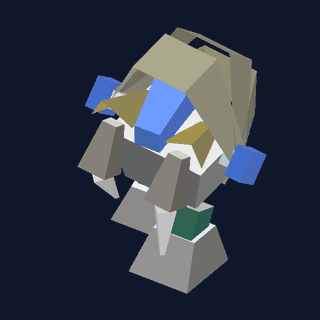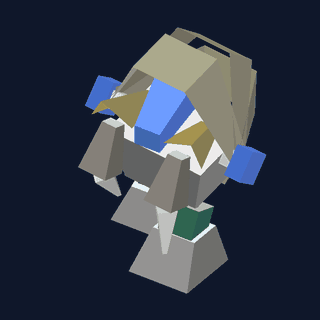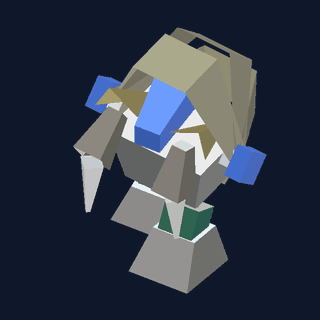
COB timeline (ARMFARK.COB)
- 0.00–1.36 s — Rest pose (the seam pose) | walk() — one full stride cycle (compiled slides; form-(c) legs run past the sleep clock)
- 1.36–2.24 s — activatescr() — arms lower and raise, lathes pitch to the work angle, torso leans into the working stance (the nano work pose)
- 2.24–3.05 s — deactivatescr() — arms and lathes fold back to the rest stance (the compiled staged close)
- 3.05–4.41 s — walk() again, then settle — the loop restarts seam-clean from the rest pose
Every stage duration equals its COB sleep exactly; values are raw COB units (turns: BAM 65536 = 360°, moves: elmo × 163840). Renderer conversions follow the proven family conventions (_cob_anim.py).