COB-exact: timeline 1:1 from armjeth.cob (gait (walk cycle), disassembled with _cob_dis.py). StateChg staged-deploy family: 2 open stages, then the compiled close order — not a reversed activate. Fire/hit/death/smoke scripts are engine-driven or firing-only and not part of this loop.
Animation
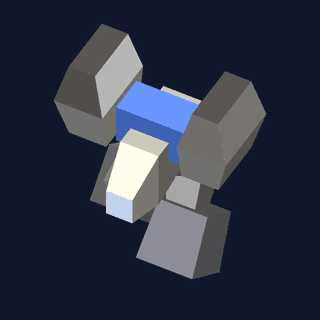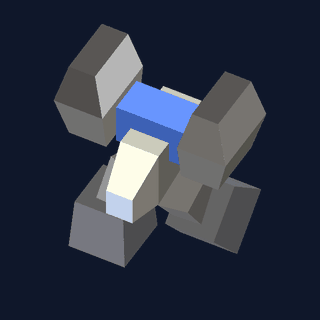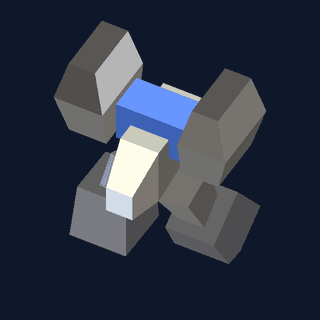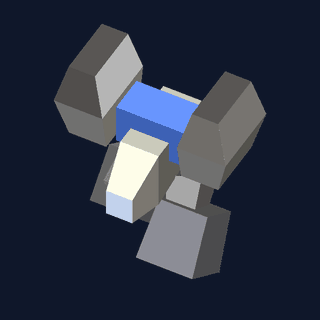
PNG frames
Frame 0 / 250.00 s
COB timeline (ARMJETH.COB)
- 0.00–1.02 s — walk() — stride cycle 1 of 2 (1020 ms): full leg/arm swing from the compiled keyframes (pelvis bob included)
- 1.02–2.04 s — stride cycle 2 (1020 ms) — proven periodic (cycle ends match per channel), loop restarts seam-clean at the stride boundary
Every stage duration equals its COB sleep exactly; values are raw COB units (turns: BAM 65536 = 360°, moves: elmo × 163840). Renderer conversions follow the proven family conventions (_cob_anim.py).